International conferences

9 international conference papers, newest first.

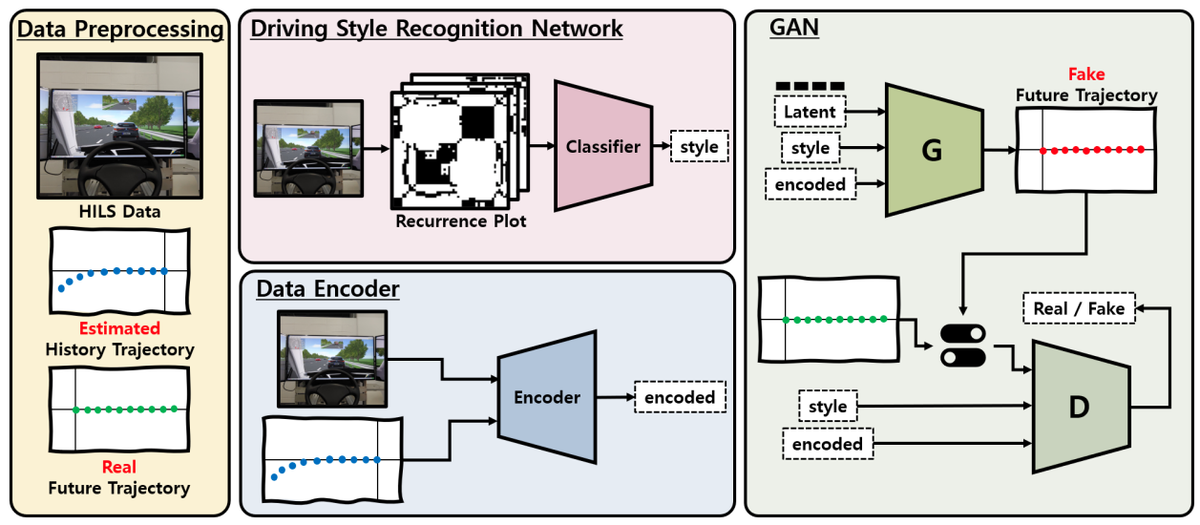
Figure from C9: DSA-GAN: driving style attention generative adversarial network for vehicle trajectory prediction
C9 · 2021
DSA-GAN: driving style attention generative adversarial network for vehicle trajectory prediction
Seungwon Choi, Nahyun Kweon, Chanuk Yang, Dongchan Kim, Hyukju Shon, Jaewoong Choi, Kunsoo Huh*
IEEE International Intelligent Transportation Systems Conference (ITSC)
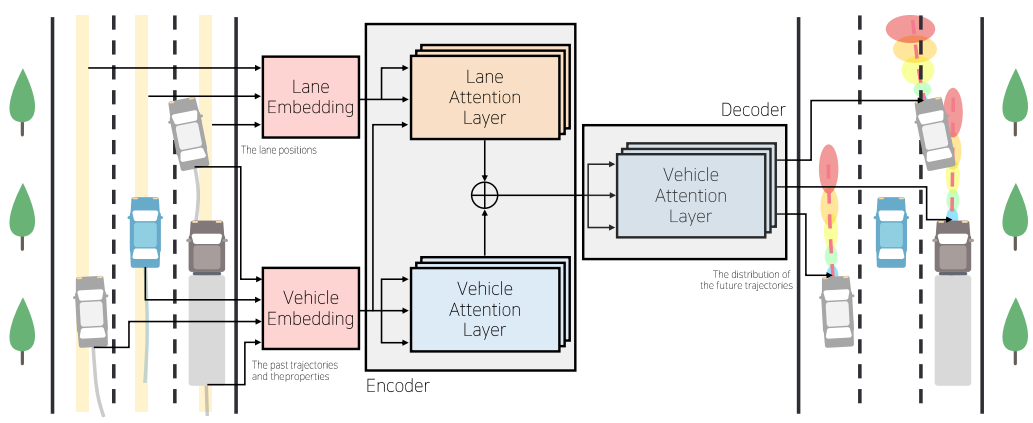
Figure from C8: Multi-head attention based probabilistic vehicle trajectory prediction
C8 · 2020
Multi-head attention based probabilistic vehicle trajectory prediction
Hayoung Kim, Dongchan Kim, Gihoon Kim, Jeongmin Cho, Kunsoo Huh*
IEEE Intelligent Vehicles Symposium (IV)
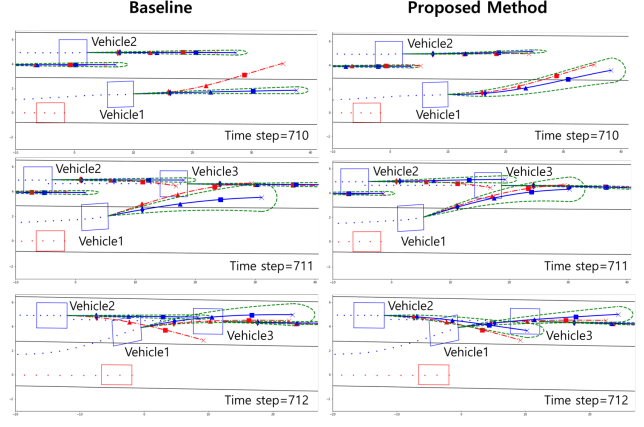
Figure from C7: Interaction aware trajectory prediction of surrounding vehicles with interaction network and deep ensemble
C7 · 2020
Interaction aware trajectory prediction of surrounding vehicles with interaction network and deep ensemble
Kyushik Min, Hayoung Kim, Jongwon Park, Dongchan Kim, Kunsoo Huh*
IEEE Intelligent Vehicles Symposium (IV)
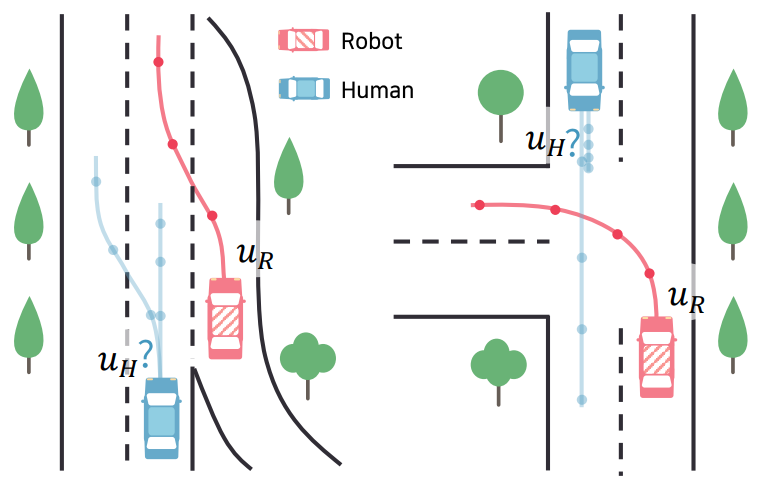
Figure from C6: Action conditioned response prediction with uncertainty for automated vehicles
C6 · 2019
Action conditioned response prediction with uncertainty for automated vehicles
Hayoung Kim, Gihoon Kim, Jongwon Park, Kyushik Min, Dongchan Kim, Kunsoo Huh*
ISPACS — Best Paper Award
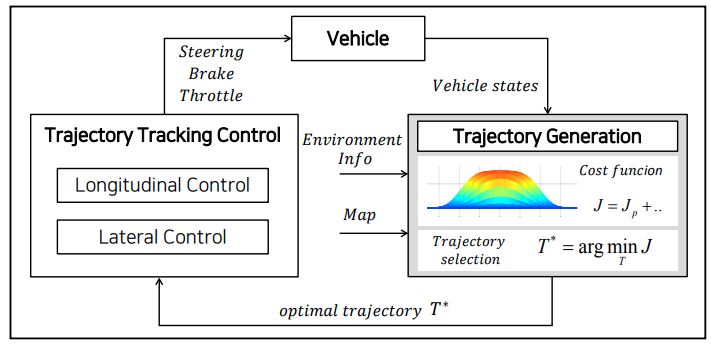
Figure from C5: Autonomous vehicle trajectory planning and control based on traffic motion prediction
C5 · 2019
Autonomous vehicle trajectory planning and control based on traffic motion prediction
Yuho Song, Dongchan Kim, Kunsoo Huh*
ISPACS
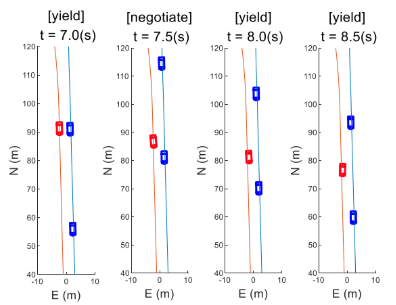
Figure from C4: Intention aware motion planning with model predictive control in highway merge scenario
C4 · 2019
Intention aware motion planning with model predictive control in highway merge scenario
Hayoung Kim, Dongchan Kim, Kunsoo Huh*
SAE Technical Paper
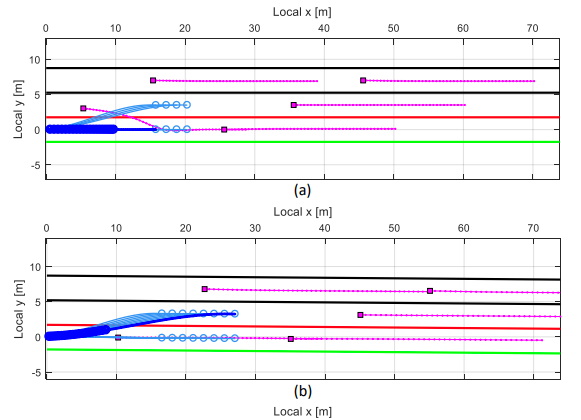
Figure from C3: Trajectory planning for autonomous highway driving using the adaptive potential field
C3 · 2018
Trajectory planning for autonomous highway driving using the adaptive potential field
Dongchan Kim, Hayoung Kim, Kunsoo Huh*
IEEE ITSC
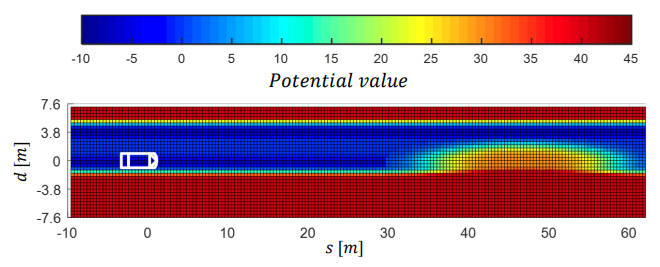
Figure from C2: Local trajectory planning and control for autonomous vehicles using the adaptive potential field
C2 · 2017
Local trajectory planning and control for autonomous vehicles using the adaptive potential field
Dongchan Kim, Hayoung Kim, Kunsoo Huh*
IEEE CCTA
Figure from C1: Intervention minimized semi-autonomous control using decoupled model predictive control
C1 · 2017
Intervention minimized semi-autonomous control using decoupled model predictive control
Hayoung Kim, Jeongmin Cho, Dongchan Kim, Kunsoo Huh*
IEEE Intelligent Vehicles Symposium (IV)